Embodied Intelligence Networks (EIN)
A full-day workshop on the network architectures, protocols, algorithms, and system designs for embodied intelligence networks, with two highlighted themes this year: multi-agent embodied systems, and virtual and real clients in embodied AI.
Overview
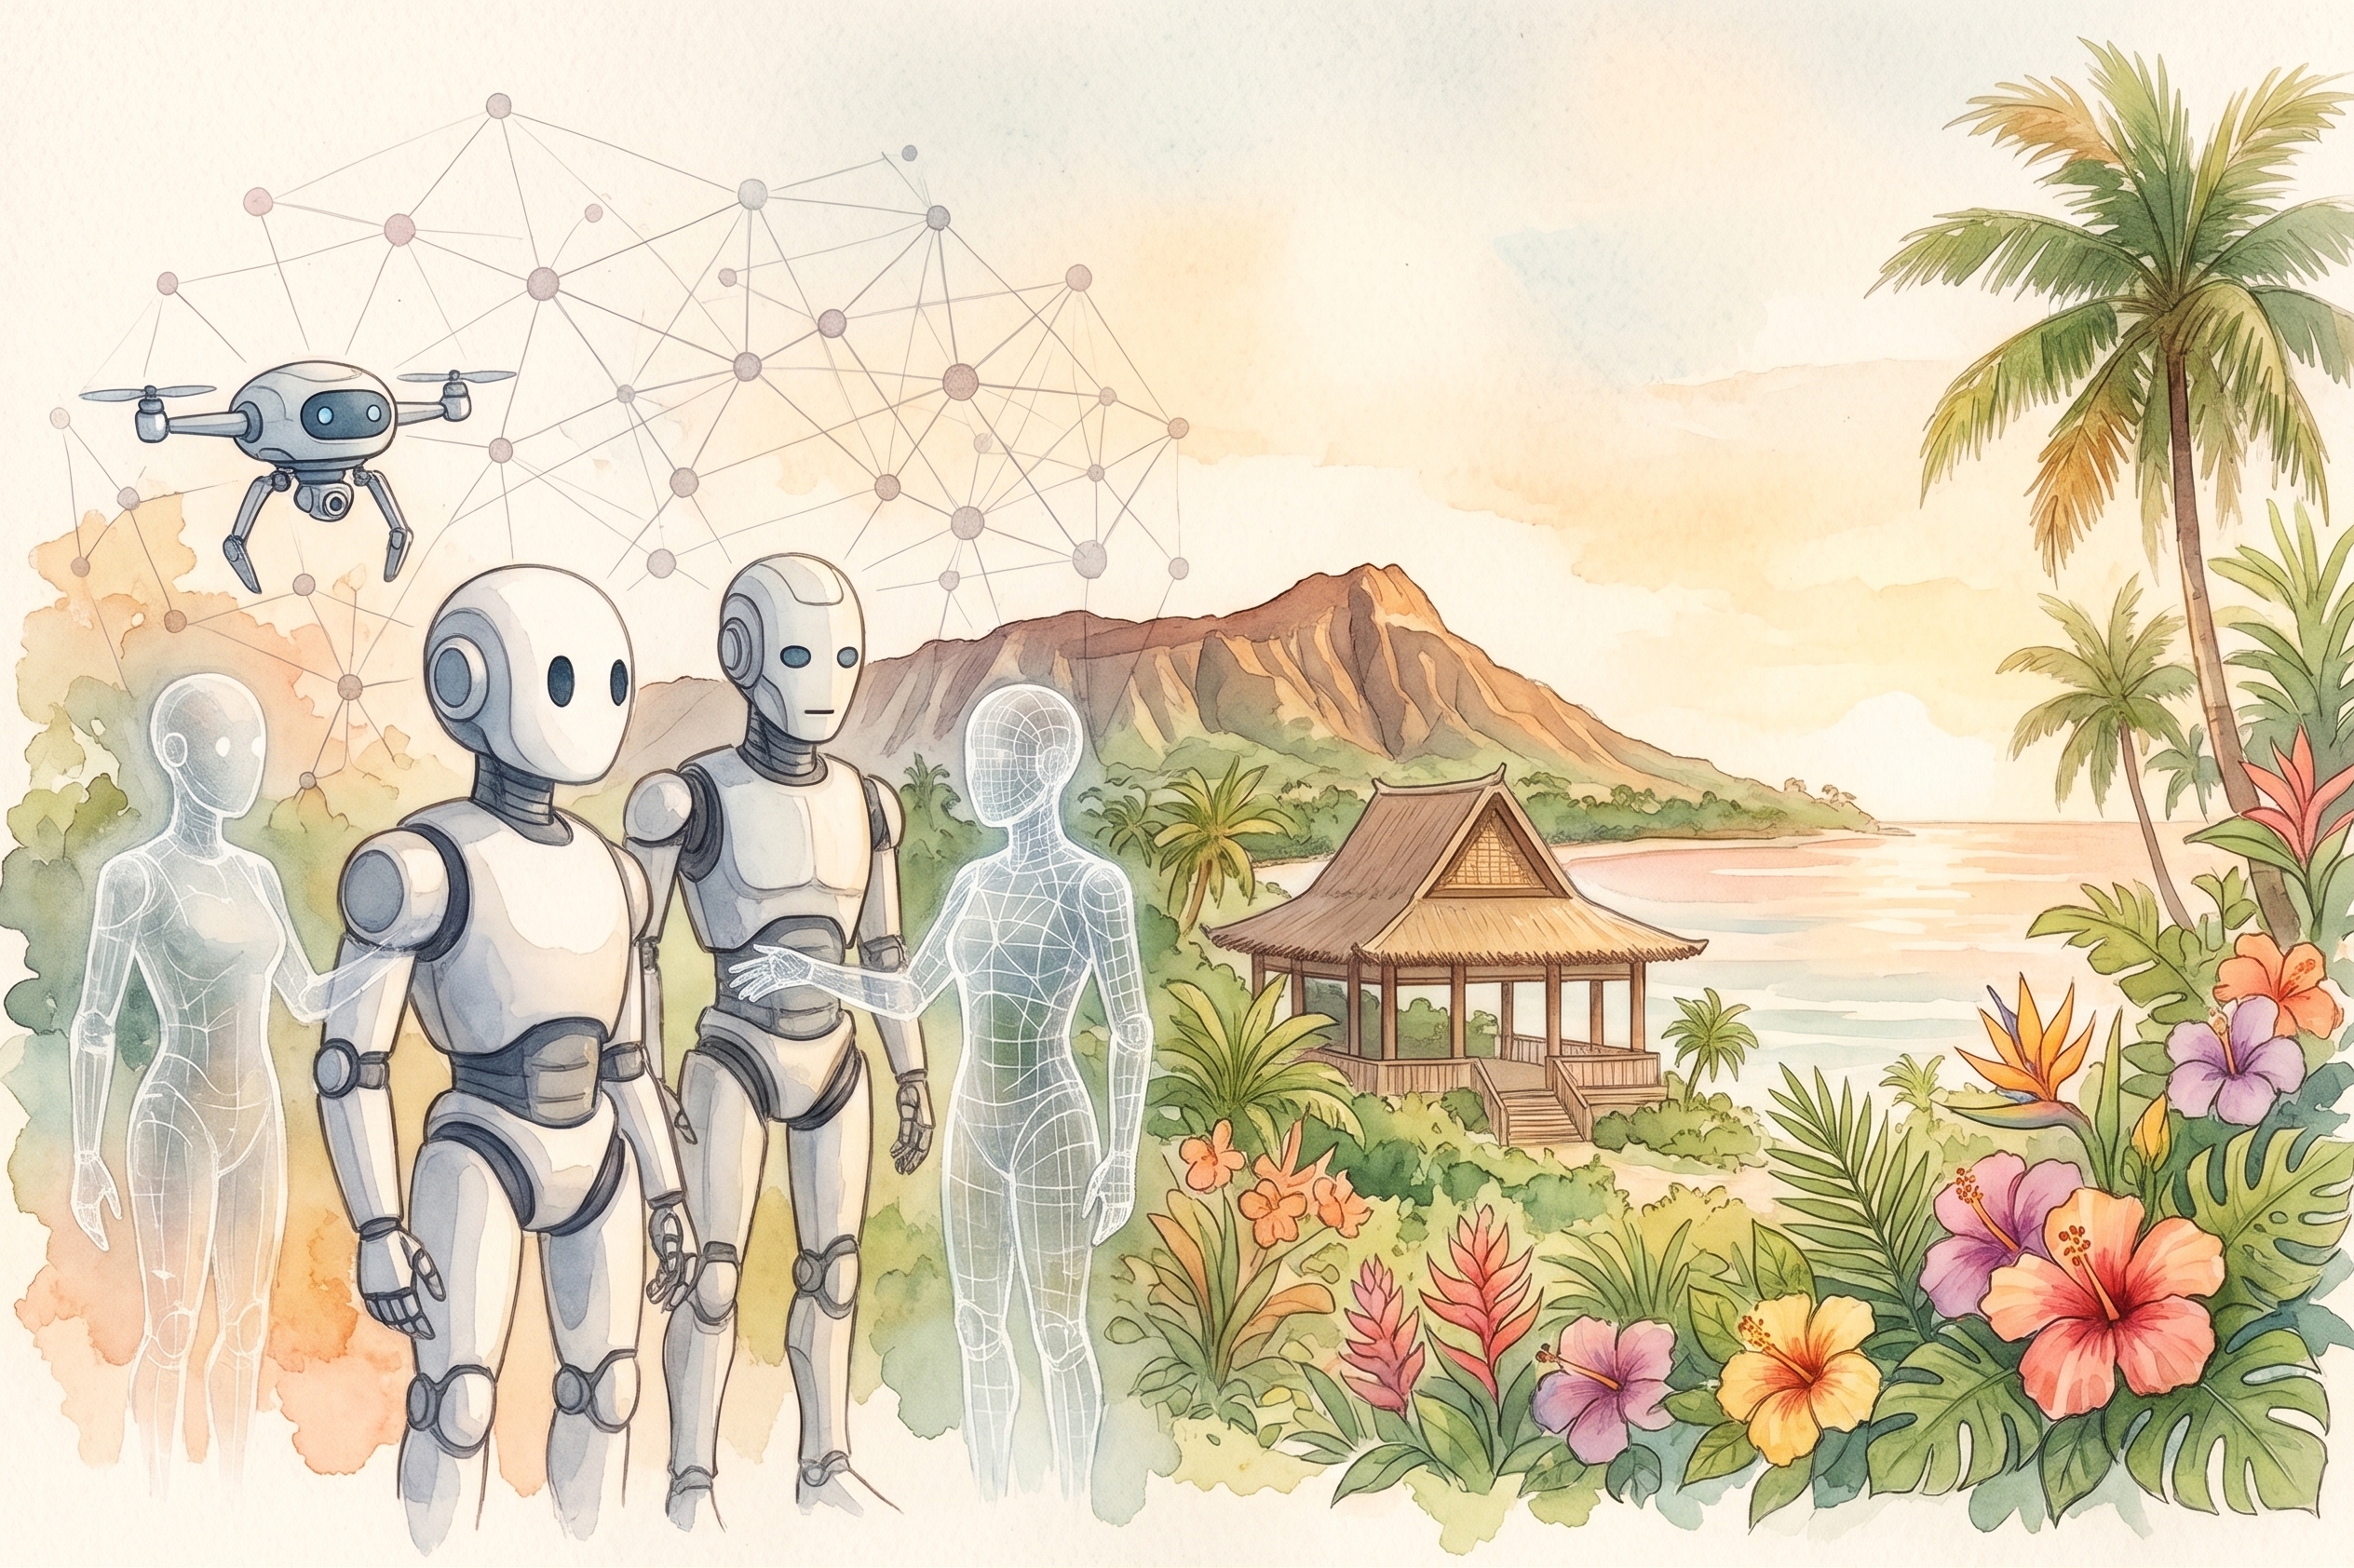
The Workshop on Embodied Intelligence Networks (EIN) studies the networks that embodied agents depend on. Embodied agents, such as collaborative robots, humanoids, smart glasses, and industrial IoT sensors, perceive and act in the physical world, increasingly under the direction of software agents that plan, call tools, and coordinate with one another. Together they form an embodied intelligence network: an intelligent mesh of actors that communicate by message passing, adapt to their environment, understand human intent, coordinate multi-agent activities, and close real-time control loops.
EIN covers the network architectures, protocols, algorithms, and system designs for such networks. Two shifts in embodied AI define this second edition.
Highlighted Themes
From one agent to many. Embodied intelligence is rarely a single robot acting alone: a warehouse fleet shares one map and divides the work, a humanoid hands a part to a robot arm, and a software agent splits one request into subtasks for several physical agents. In these multi-agent embodied systems, the network is the medium of coordination. What each agent knows depends on which messages reach it and when, coordination messages compete with sensor streams for the same wireless links, and a collective decision is only as good as its least-informed participant. Networking many agents so that they act as a team, rather than as individuals that happen to share a channel, is our first highlighted theme.
Virtual and real, side by side. Embodied systems now involve two populations of clients. Virtual clients (software agents, simulated robots, and digital-twin replicas) are cheap, fast, and plentiful, but only approximate the world; real clients (physical robots, wearables, and IoT devices) are scarce and costly, but they are where actions take effect. The two increasingly work together: a robot policy is trained across thousands of simulated robots and a handful of physical ones; a digital twin plans a maneuver that a real robot executes; a testbed surrounds a few real devices with thousands of virtual clients. The network between them determines whether they stay consistent, and whether what works in the virtual world holds in the real one. Networking virtual and real clients is our second highlighted theme.
Workshop Themes
The workshop is organized around four themes, each anchoring one of its four paper sessions:
- Multi-agent embodied systems (highlighted)
- Virtual and real clients in embodied AI (highlighted)
- Network infrastructure for embodied foundation models, such as vision-language-action (VLA) models and world models
- Dependable embodied networks
EIN solicits short technical papers of up to six pages, each presented as a talk, and favors early results, visionary ideas, and open-source artifacts. See the Call for Papers for the full list of topics.
Important Dates
- Submission deadline
- December 29, 2026
- Notification of acceptance
- February 2, 2027
- Camera-ready manuscript due
- February 16, 2027
- Workshop date
- Monday, May 24, 2027
- Workshop format
- Full-day event held in conjunction with IEEE INFOCOM 2027 in Honolulu, Hawaii, USA
Dates may be adjusted to follow the final IEEE INFOCOM 2027 workshop schedule; please check back for updates.
Workshop Program
EIN 2027 is a full-day workshop featuring a keynote, four one-hour paper sessions (one per theme), and a one-hour panel after lunch, “Virtual clients, real clients, and the network between them,” bringing together panelists from networking, multi-agent systems, robotics, and machine learning systems. The day closes with a Best Paper Award.
Speakers and the detailed program will be announced on the program page.
Past Edition
EIN 2026 was held as a half-day workshop at IEEE INFOCOM 2026 in Tokyo, Japan, on May 18, 2026. It featured ten peer-reviewed papers, by authors from eight countries and regions, in three sessions: Federated Learning for Embodied Intelligence; Adaptive and Collaborative Embodied Intelligence; and Systems, Security, and Optimization for Embodied AI Infrastructure. György Dán (KTH Royal Institute of Technology) gave the keynote, “From Pixels to Policies: Securing the Perception–Action Loop in Networked Embodied Intelligence.”